
Blog posts tagged "ROS2"
October came, and October went. Happy November everybody. This month, since last month was quite Ubuntu robotics heavy, the focus is more on you. For you....
Hey everyone, listen up, ROSCon 2019 is days away, and the Ubuntu team is going to be there. If you’re coming to Macau be sure to come and say hi at booth 22....
The Ubuntu robotics team presents, The State of Robotics. A monthly blog series that will round up exciting news in robotics, discuss projects using ROS, and...
We at Canonical have been hard at work on the security features of version 2 of the Robot Operating System (ROS 2). However, if we lift our collective heads...
ROSCon Japan 2019 was a resounding success. We took in the keynote speech from Ryan Gariepy, Co-founder and CTO of Clearpath Robotics. We demoed the first...
After exploring some ROS 2 subtleties and implementing some CLI tools we felt were missing, the time has come to get our hands even more dirty. What better...
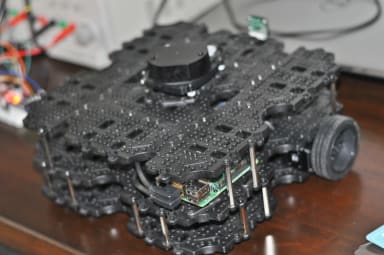
TurtleBot3 was released in 2017 and is positioned as a low-cost, open-source robot kit. For new owners of the TurtleBot3, there are various resources online...
We at Canonical care deeply about robotics. We firmly believe that robots based on Linux are cheaper to develop, more flexible, more secure, and faster to...
After our series of post about ROS 2 CLI tools (1, 2), we continue exploring the ROS 2 realm taking a look at ROS 2 components and more specifically, how they...
A well configured linter can catch common errors before code is even run or compiled. ROS 2 makes it easy to add linters of your choice and make them part of...
One of the most common complaints from developers moving into large Python codebases is the difficulty in figuring out type information, and the ease by which...
Following our previous post on ROS 2 CLI (Command Line Interface), we will see here how one can extend the set of existing CLI tools by introducing a new...
Disclosure: read the post until the end, a surprise awaits you! Moving from ROS 1 to ROS 2 can be a little overwhelming.It is a lot of (new) concepts, tools...
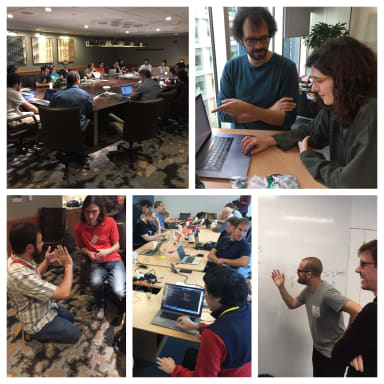
Following previous events in New York, Seattle, and London, the fourth Snapcraft Summit is taking place in Montreal, Canada from June 11th to 13th 2019. We...
When using the Robot Operating System (ROS), it’s fairly common to want to shut down a launched system if a specific node (or set of nodes) exits. This is...
- Previous page
- 1
- 2
- 3
- Next page