
Blog posts tagged "ROS2"
Welcome to Part 2 of the “optimise your ROS snap” blog series. Make sure to check Part 1 before reading this blog post. This second part is going to present...
Do you want to optimise the performance of your ROS snap? We reduced the size of the installed Gazebo snap by 95%! This is how you can do it for your snap....
Application orchestration is the process of integrating applications together to automate and synchronise processes. In robotics, this is essential,...
If you already tried to package ROS 2 Foxy applications into snaps, you might have encountered the following error regarding shared memory: This log is...
Today, Foxglove announced the release of the Foxglove Studio snap. Foxglove Studio helps you experience the world as a robot does, providing a rich set of...
We’re excited about the recent release of ROS 2 Humble Hawksbill, a Long Term Support (LTS) distro, supported for the next five years. ROS 2 releases come out...
We welcome the new release of ROS 2 Humble which targets the recently released Ubuntu 22.04. If you want to install it now, please visit the ROS 2 Humble...
Learn more about DDS, and how to stay protected while using it If you are currently running the Robot Operating System 2 (ROS 2), this piece is especially...
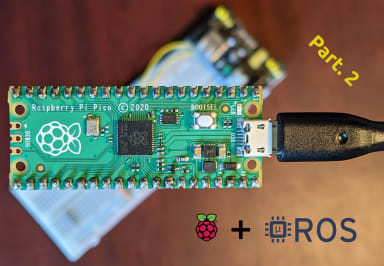
In this post, we will see how to wire up an HC-SR04 range sensor to the Raspberry Pi Pico and publish its readings to the ROS 2 graph using micro-ROS. This...

Canonical ROS ESM customers now can access a long-term supported ROS and Ubuntu environment by the Ubuntu and ROS experts. Learn more about ROS ESM. 6 April...
In this post we will see how the Raspberry Pi Pico can natively speak to a ROS 2 graph using micro-ROS. We will set up a project in VSCode, compile and upload...
Goodbye Thanksgiving (well, for some of us), hello Christmas! The holiday season really is the best, and it always brings interesting robotics news, which we...
Construct a prototype ROS 2 system distributed across multiple computers using Kubernetes. Our goal is not only to provide you with a working configuration,...
The myriad of different fields that make up robotics makes QA practices difficult to settle on. Field testing is the go-to, since a functioning robot is often...
ROS, the Robot Operating System, is the platform of choice for robot development. However, the breadth and depth of existing documentation can be daunting for...
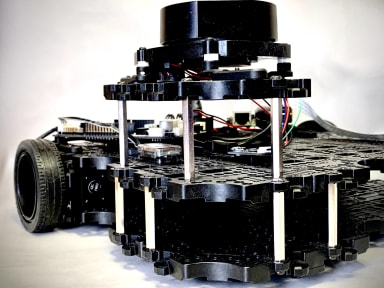
Interested in getting started in robotics? There’s no need to purchase expensive hardware before you try some things out: simulate a TurtleBot3 instead! The...