
Blog posts tagged "Robots"
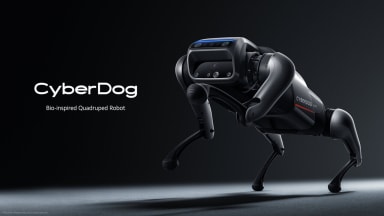
Late this year, Chinese tech giant Xiaomi unveiled CyberDog: a quadrupedal, experimental, open-source robot that the firm claims will improve the robot...
Introduction Our simple ROS 2 talker and listener setup runs well on a single Kubernetes node, now let’s distribute it out across multiple computers. This...
Kubernetes and ROS make a great match, but ROS2 can be tricky to set up. In this post we demonstrate a scalable system with MicroK8s on Ubuntu.
ROS, the Robot Operating System, is the platform of choice for robot development. However, the breadth and depth of existing documentation can be daunting for...
The snapcraft CLI (the tool used to create snaps) has long had support for building snaps that use both ROS 1 and ROS 2. ROS 2 Foxy Fitzroy is the latest ROS...
Interested in getting started in robotics? There’s no need to purchase expensive hardware before you try some things out: simulate a TurtleBot3 instead! The...
We’re pleased to announce that the Center for Internet Security (CIS) has publicly released the ROS Security Benchmark for community discussion. When...
It’s the season for updates. The last few weeks have ushered in ROS 1 Noetic and ROS 2 Foxy, both of which target the recently released Ubuntu 20.04 Focal...
November, for robotics, was a good month. We’re seeing new things develop, current projects finish and more cute animals in our future. So who can complain?...
We recently got an interesting question from a customer, and I think the answer might be helpful to a wider audience. Python 2 will reach end of life in two...
Lifecycle management entails fulfilling changing requirements over time. However, there is a gap that the existing robot development frameworks do not...
Robots are an increasingly important part of our lives, in more ways than we realise. I’m not talking just about Roombas, or the toy robots that inhabit the...
The home for innovators, Ubuntu is a place where developers can create what previously lived solely in the realms of fiction. The internet of things, the...
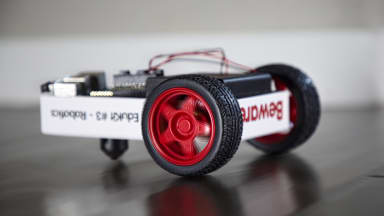
This is the fifth (and final) blog post in this series about creating your first robot with ROS and Ubuntu Core. In the previous post we discussed methods of...
This is the fourth blog post in this series about creating your first robot with ROS and Ubuntu Core. In the previous post we worked on getting data out of...
This is the third blog post in this series about creating your first robot with ROS and Ubuntu Core. In the previous post you were introduced to the Robot...